Last updated: recently
| MCU | STM32H743 Cortex-M7 |
| Clock Speed | 480 MHz |
| Flash Memory | 2 MB |
| RAM | 1 MB |
| IMU | BMI270 (Accelerometer + Gyroscope) |
| IMU (Alt) | BMI088 (Accelerometer + Gyroscope) |
| Barometer | DPS368, precision barometric pressure sensor |
| Magnetometer | IST8310 |
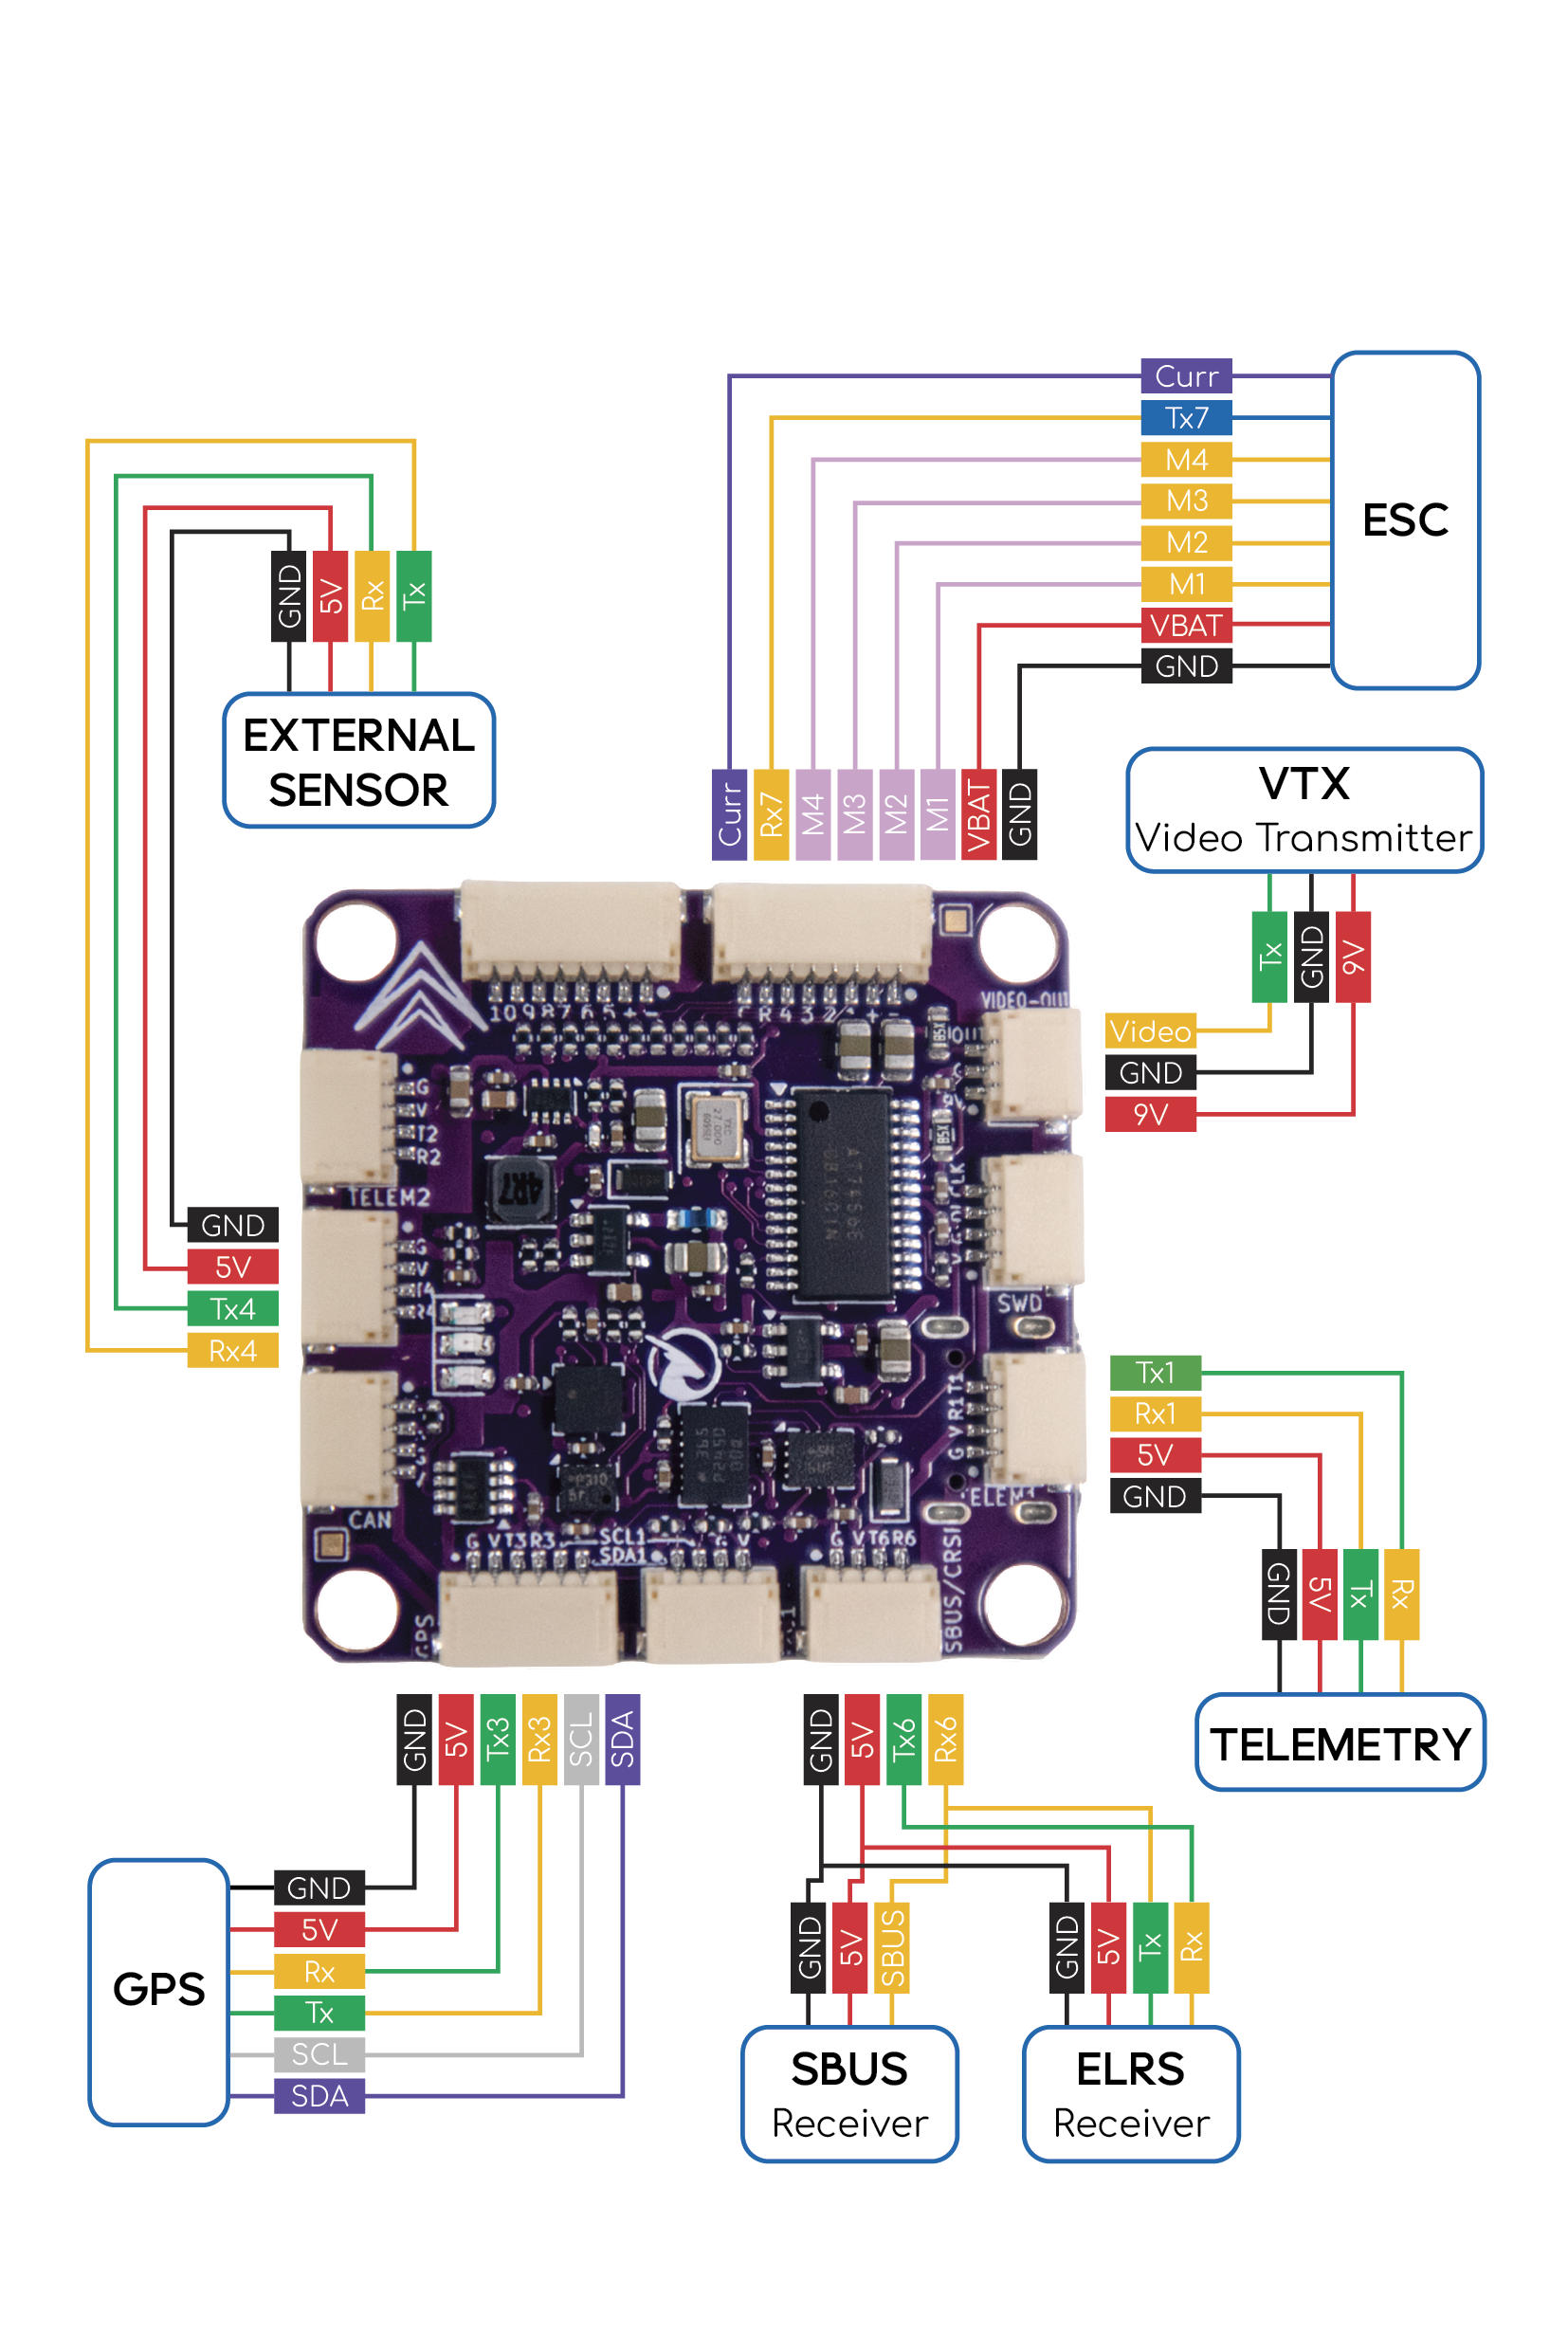
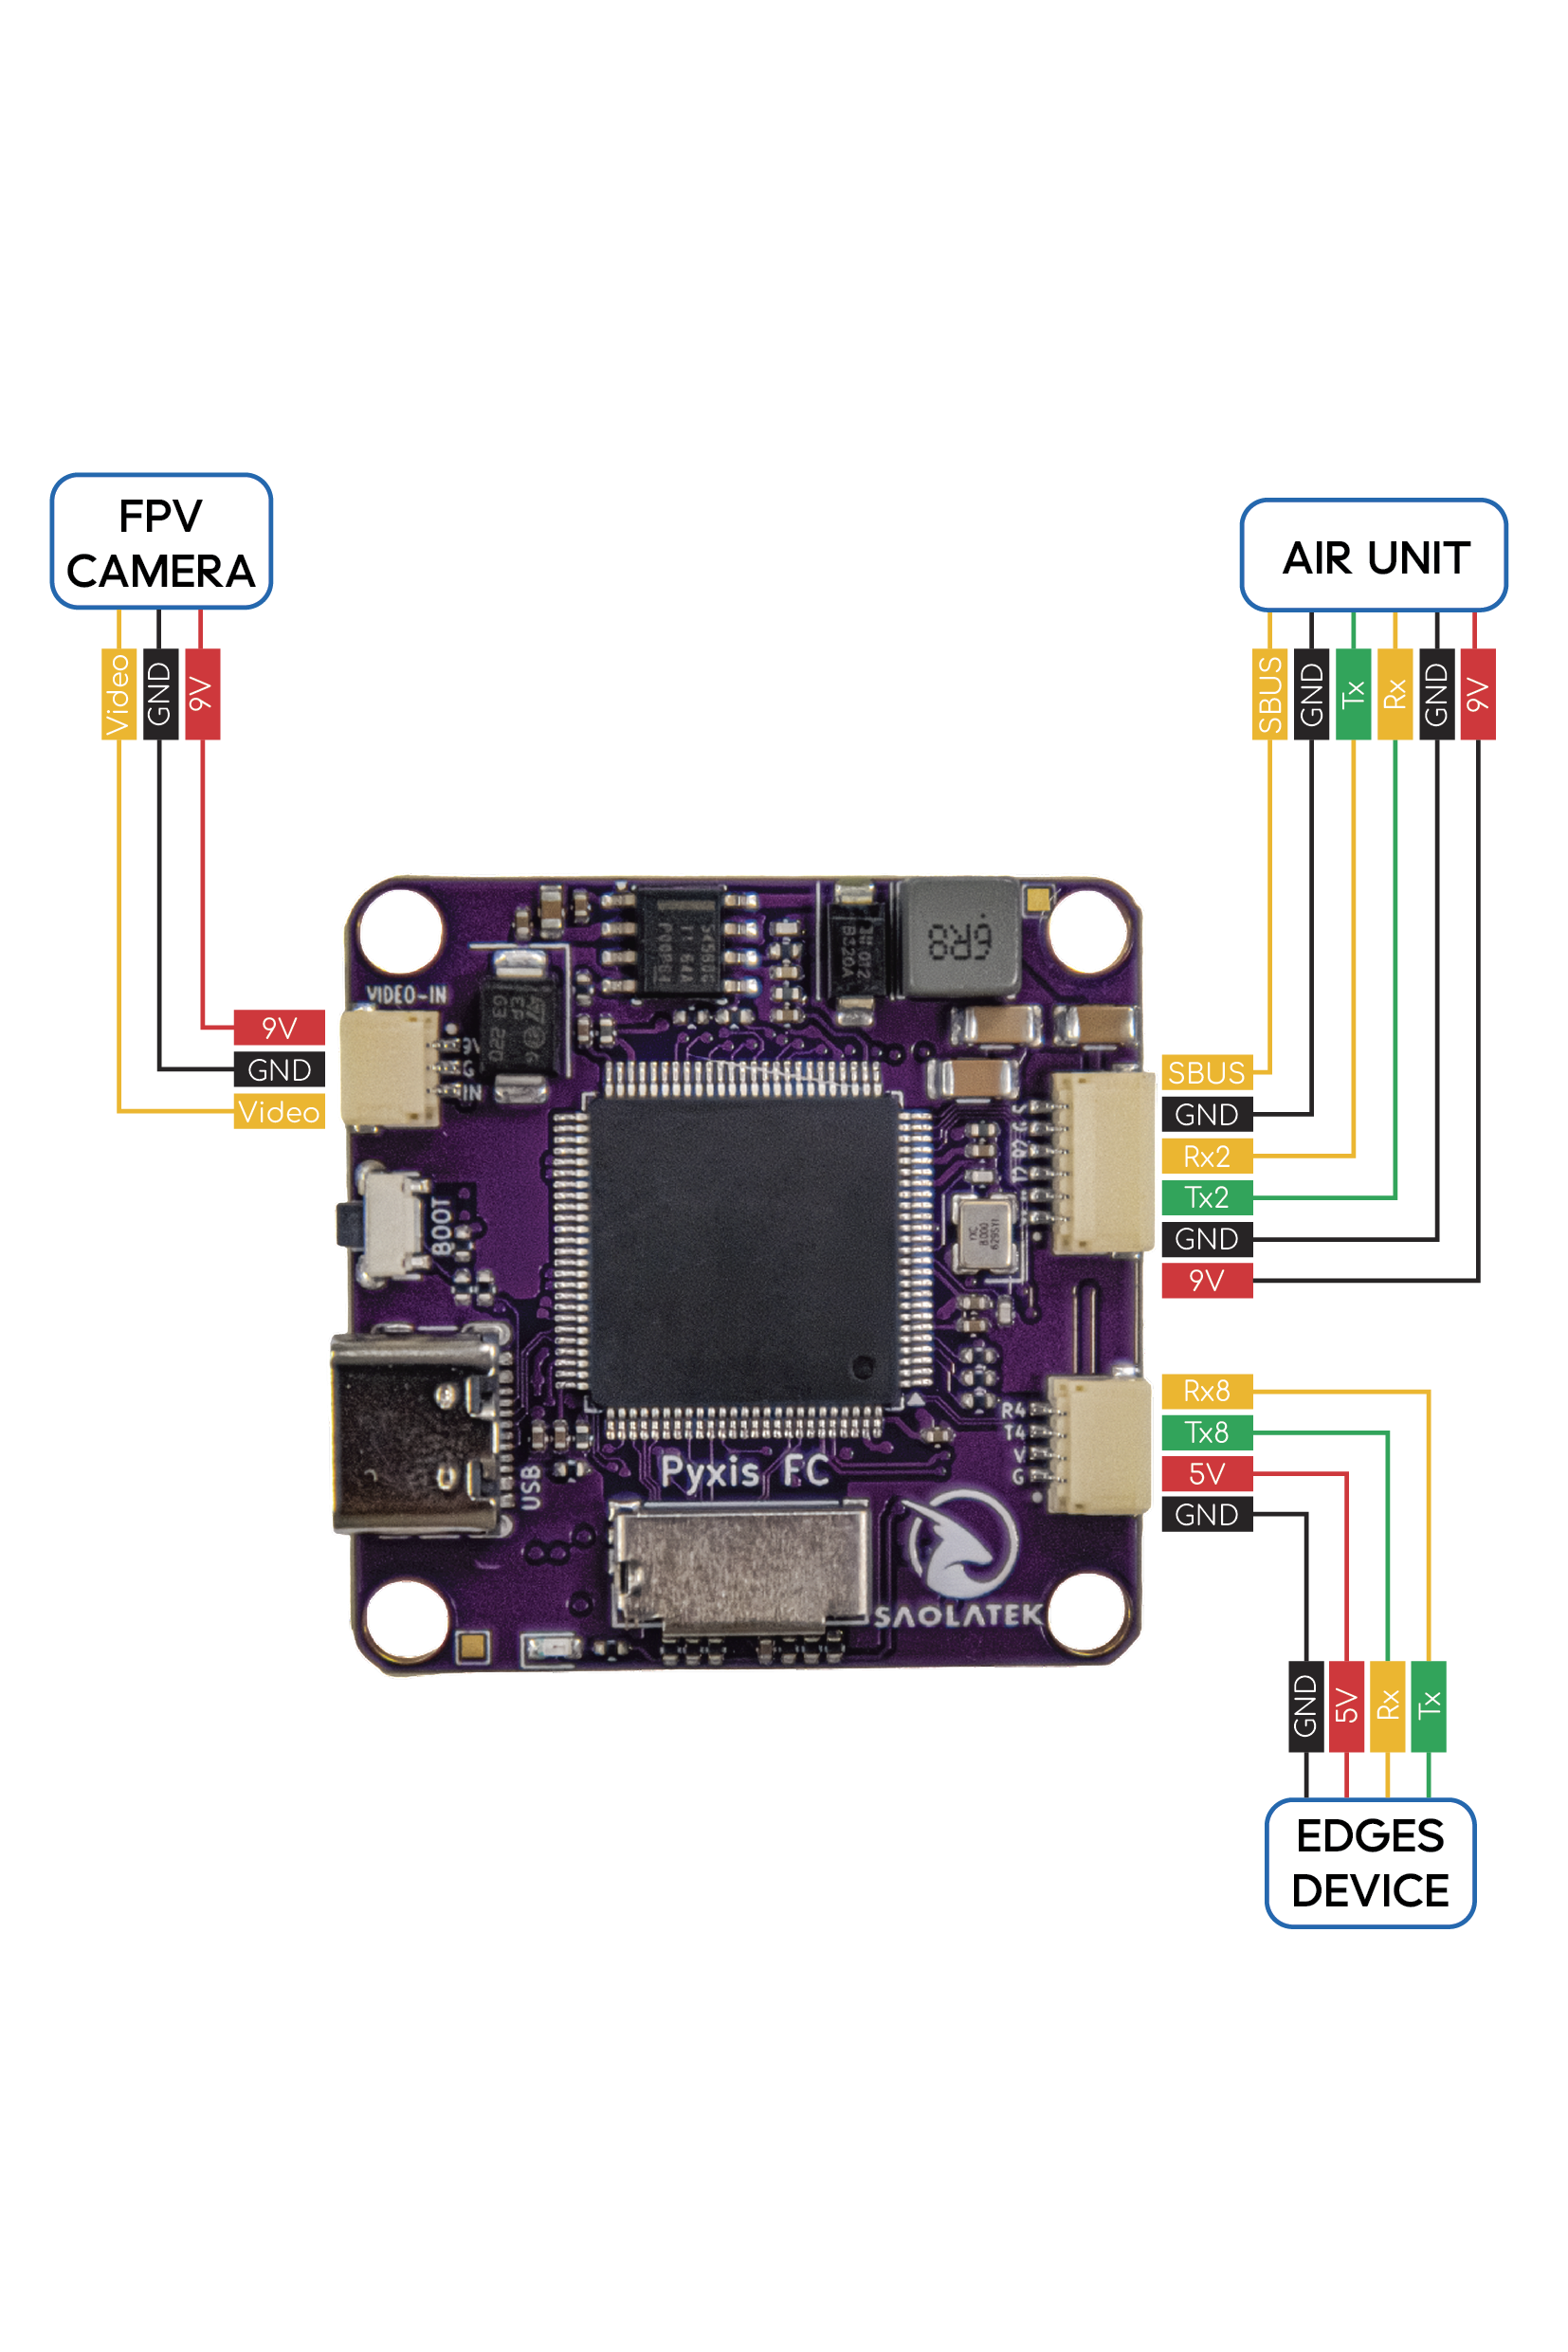
| Serial Ports | 7x UART (UART1–4, 6–8) + 1x USB VCP |
| USB | Type-C, Virtual COM Port (VCP) |
| CAN Bus | 1x interface, DroneCAN ready |
| I2C | Expansion port for external peripherals |
| PWM Outputs | Up to 10 channels |
| Protocol Support | DShot compatible |
| Bi-directional DShot | Supported on M1, M3, M5 (ESC telemetry over signal wire) |
| Input Voltage | 3S – 6S LiPo |
| 9V Rail (Camera / FC) | 9V regulated — TPS54560 buck converter |
| 5V Rail (Peripherals) | 5V regulated — TPS62932 buck converter (UART, I2C and other peripherals) |
| Local Regulation | Dedicated LDOs for MCU and IMU clusters |
| Voltage/Current Monitoring | Integrated |
| Flight Controller | Pyxis FC × 1 |
| Cables | JST-SH 1.0mm pitch: 3-pin ×2, 4-pin ×8, 6-pin ×2, 8-pin ×2 |
| MicroSD Card | 1 GB × 1 |
| Damping Silicone | × 4 |
| Mounting Hardware | M3 lock nuts × 4, M3×30 knurled thumb screws × 4 |
| Information Card | x 1 |
| Dimensions | 36 × 36 mm |
| Mounting Holes | 31 × 31 mm |
| Hole Diameter | 3.5 mm |
| Board Thickness | 8.3 mm |
| Weight | 10 g |
| OSD | AT7456E analog on-screen display |
| Blackbox Logging | MicroSD card slot |
| Voltage Monitoring | Integrated |
| Current Monitoring | 1x ADC input (CURR, from ESC) |
| Status LED | RGB |
Multirotor UAV
Stable flight performance for multi-rotor configurations
Fixed Wing Aircraft
Full support for fixed-wing airframes and control surfaces
Long Range FPV
Optimized for extended range and endurance flights
VTOL Platforms
Seamless transition between hover and forward flight modes
Ground Rover
Compatible with ground-based robotic platforms
Research & Development Projects
Open platform for custom development and experimentation


